Design, Simulation, and Performance Analysis of an INS/GPS System using Parallel Kalman Filters Structure
Abstract
Thanks to the strong growth of MEMS technology, the Inertial Navigation System (INS) is widely applied to navigation and guidance of moving objects. However, there exist errors in the inertial sensor’s signals that cause unacceptable drifts. To minimize these effects on the INS system, a GPS is usually employed simultaneously with an INS in order to increase the dimension of the system; the desired parameters are estimated by Kalman filtering technique applied to the enlarged system. In this paper, we present the design, simulation and performance analysis of an INS/GPS system using two parallel Kaman filters in order to increase the accuracy of the parameter estimation process. The results show that this system could be efficiently brought to practical applications.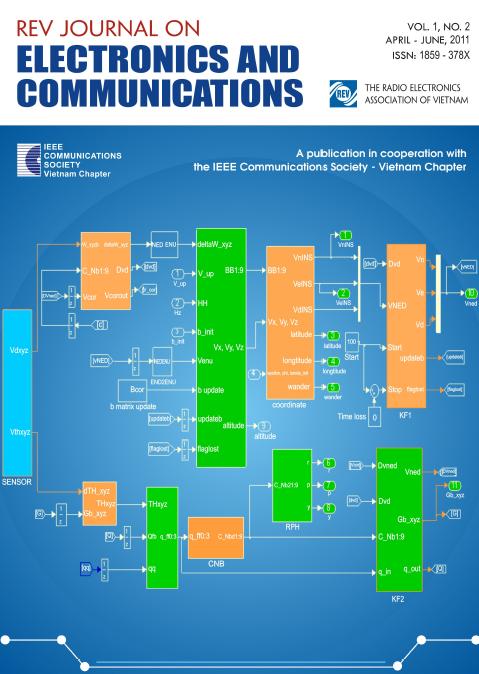
Published
2011-09-01
Section
Regular articles
An author's submission implies that the manuscript has not been published previously, and is not currently submitted for publication elsewhere. Submission also implies that the Corresponding Author has consent of all authors (the Authors). Upon acceptance for publication transfer of copyright will be made to the Publisher of REV-JEC, who guarantees that full content of the published article is freely distributed on the Journal's website. The copyright transfer gives the Publisher of REV-JEC full authority to resolve any complaints of misuse or abuse (such as infringement or plagiarism) of the published article. The Authors have the freedom to redistribute and reuse the published article in any medium or format for any purpose, provided the original published article is properly cited. An article submission implies author agreement with this policy.